Puralink
The Insight
Pipe networks underpin cities and industry, but operators often have limited visibility into their condition. Inspection remains manual and reactive because conventional tools struggle with access points, bends, junctions and vertical sections. The idea began after Harrison saw a leaking Sydney water main left unattended during severe water restrictions, only for crews to eventually dig up the road simply to locate the defect.
The Product
Puralink's ‘Ferret’ robot autonomously navigates small-diameter networks, including bends, junctions and vertical shafts, while capturing video, spatial and inertial data. PuralinkOS turns that information into digital records, condition insights and asset maps. Longer term, the team wants modular robots to live inside operating pipe networks, continuously monitoring changes and eventually repairing faults before they become catastrophic failures.
The Journey
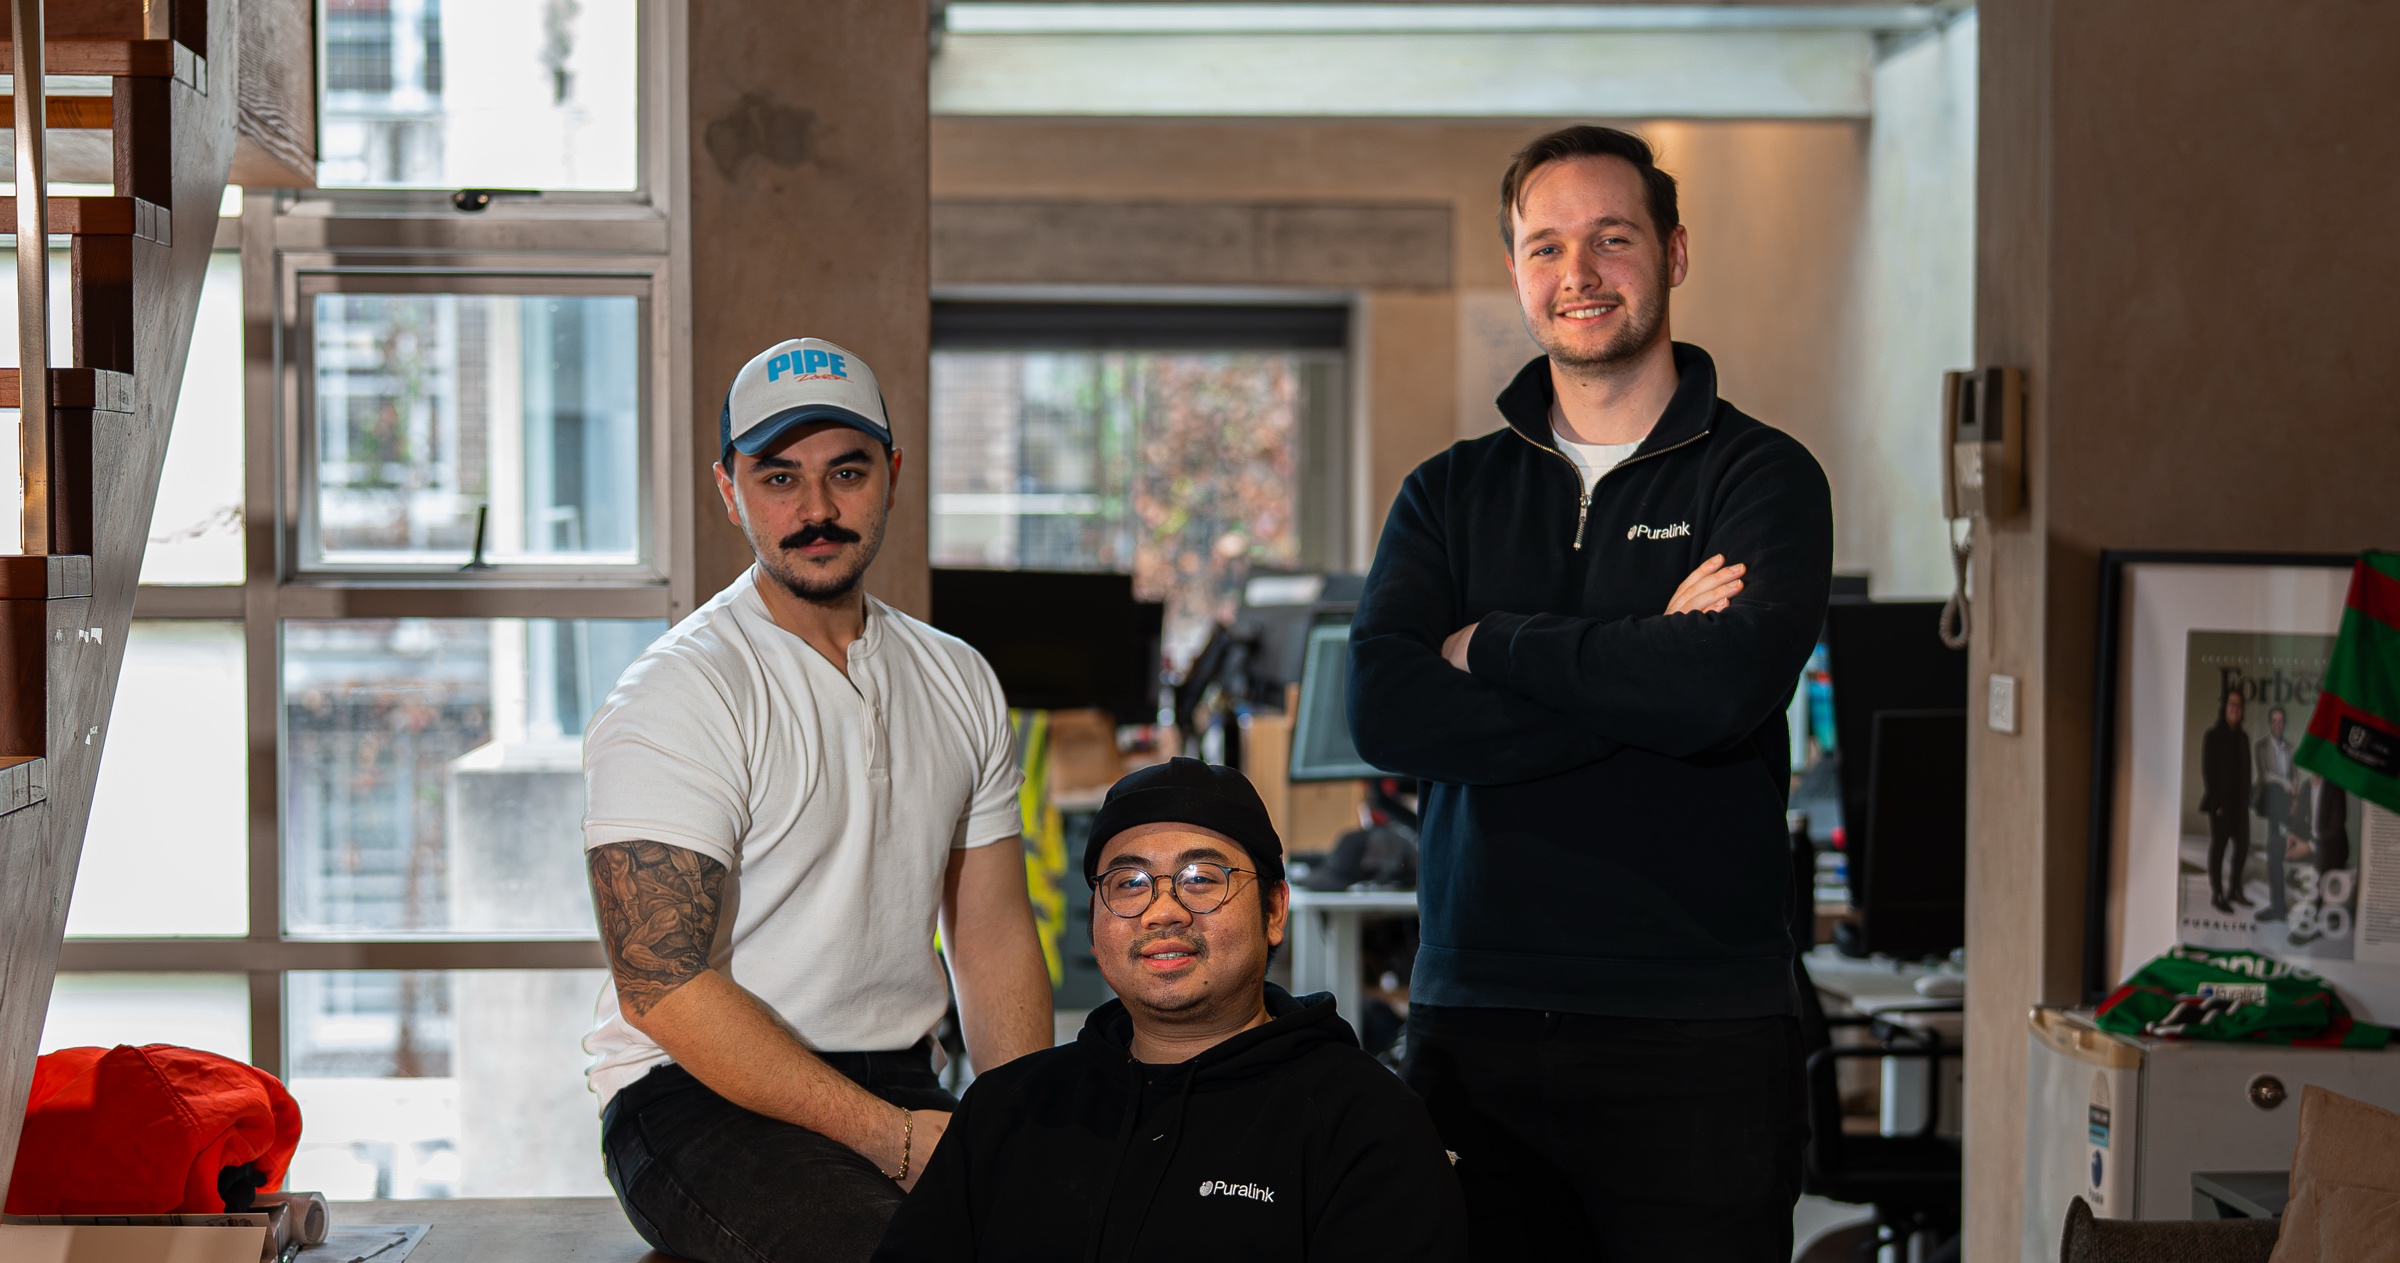
Harrison has been building robots since childhood and turned his UTS capstone research on robot mobility inside pipes into Puralink's patented drive technology. He met Shyeon at AWS, where they built an AI-powered research tool that cut a 205-hour manual process to roughly 10 to 15 minutes. Shyeon brings experience across IBM, AWS and Mastercard and leads commercial operations. Long, the company's CTO, joined the founding team after teaching with Harrison at UTS and leading teams across infrastructure and autonomous automotive projects.
The Belief
Work backwards from the real problem, iterate quickly in the field and build alongside customers. The founders place particular emphasis on ownership, evidence, safety, quality and trust, especially when customers are giving the company access to critical infrastructure.